CS223 · Chapter 1 · Annotated SlidesLinear Transformations
Original
Overview

Linear Transformations

Matrix transformations x ↦ Ax, domain, codomain and range, linearity and superposition, shear, rotation, reflection and projection examples, the standard matrix A = [T(e₁) … T(eₙ)], and one-to-one and onto transformations.

How to read this page

Every original slide is shown unchanged. Yellow marks on a slide point to a numbered note: hover or tap a mark to jump to its note, and hover a note to see its marks. Questions tagged Past exam appeared on a real paper; Prediction questions are likely angles, not confirmed. Pick an answer to each question: a wrong pick tells you why it is wrong, so you can try again.
All 33 slides
  1. 1 Introduction to Linear Transformation
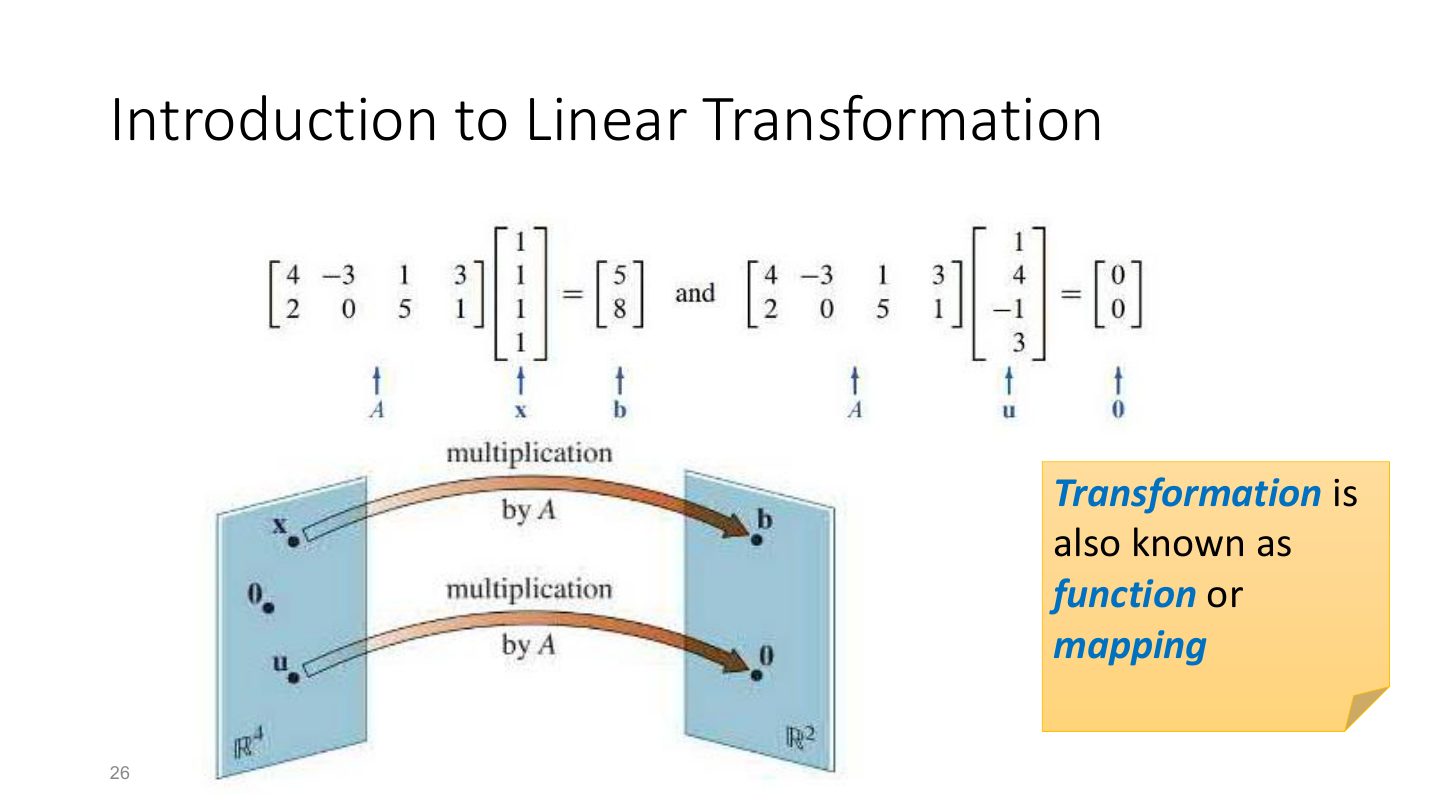
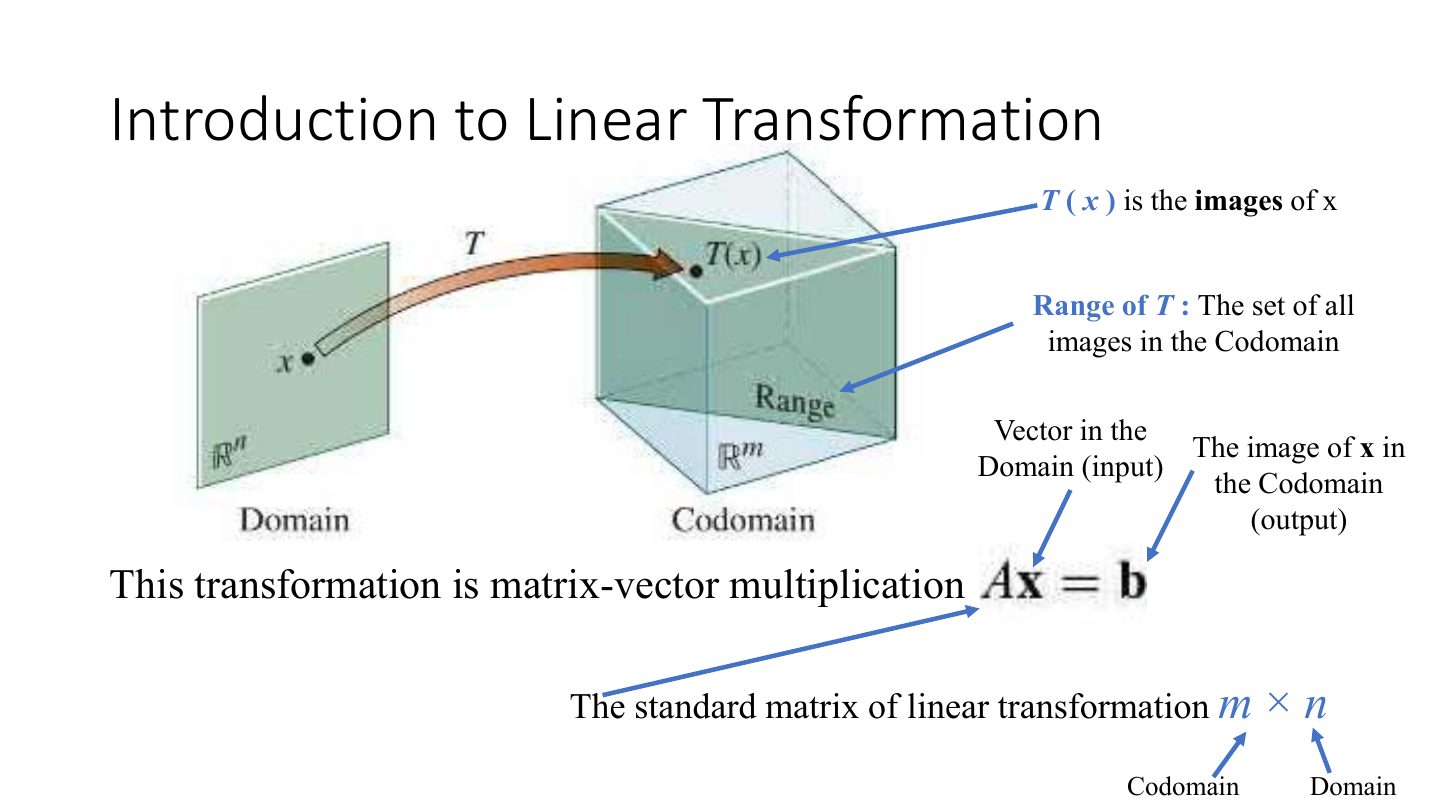
  2. 2 Introduction to Linear Transformation
  3. 3 Slide 3
  4. 4 Slide 4
  5. 5 Slide 5
  6. 6 Slide 6
  7. 7 Slide 7
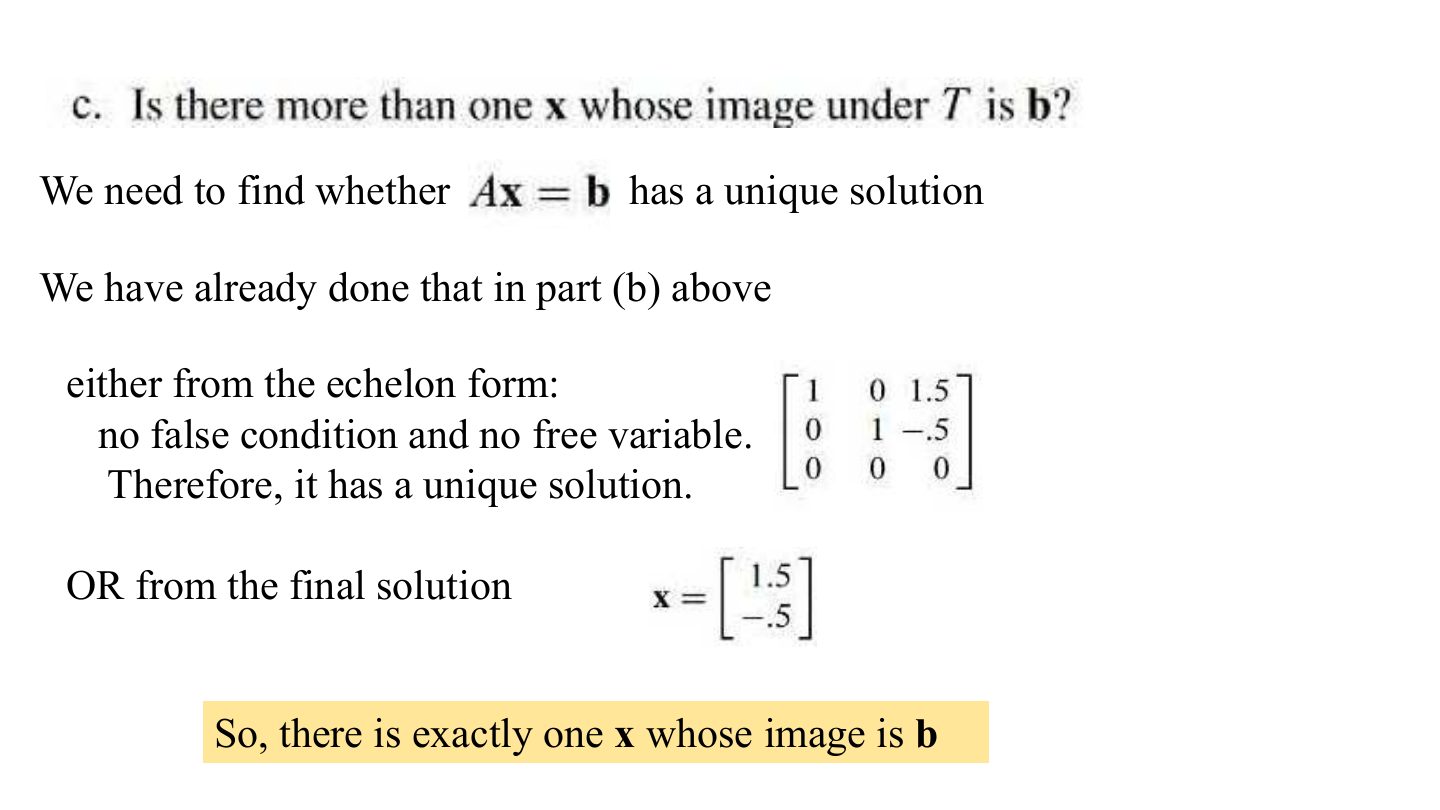
  8. 8 We need to find whether has a unique solution
  9. 9 Slide 9
  10. 10 Slide 10
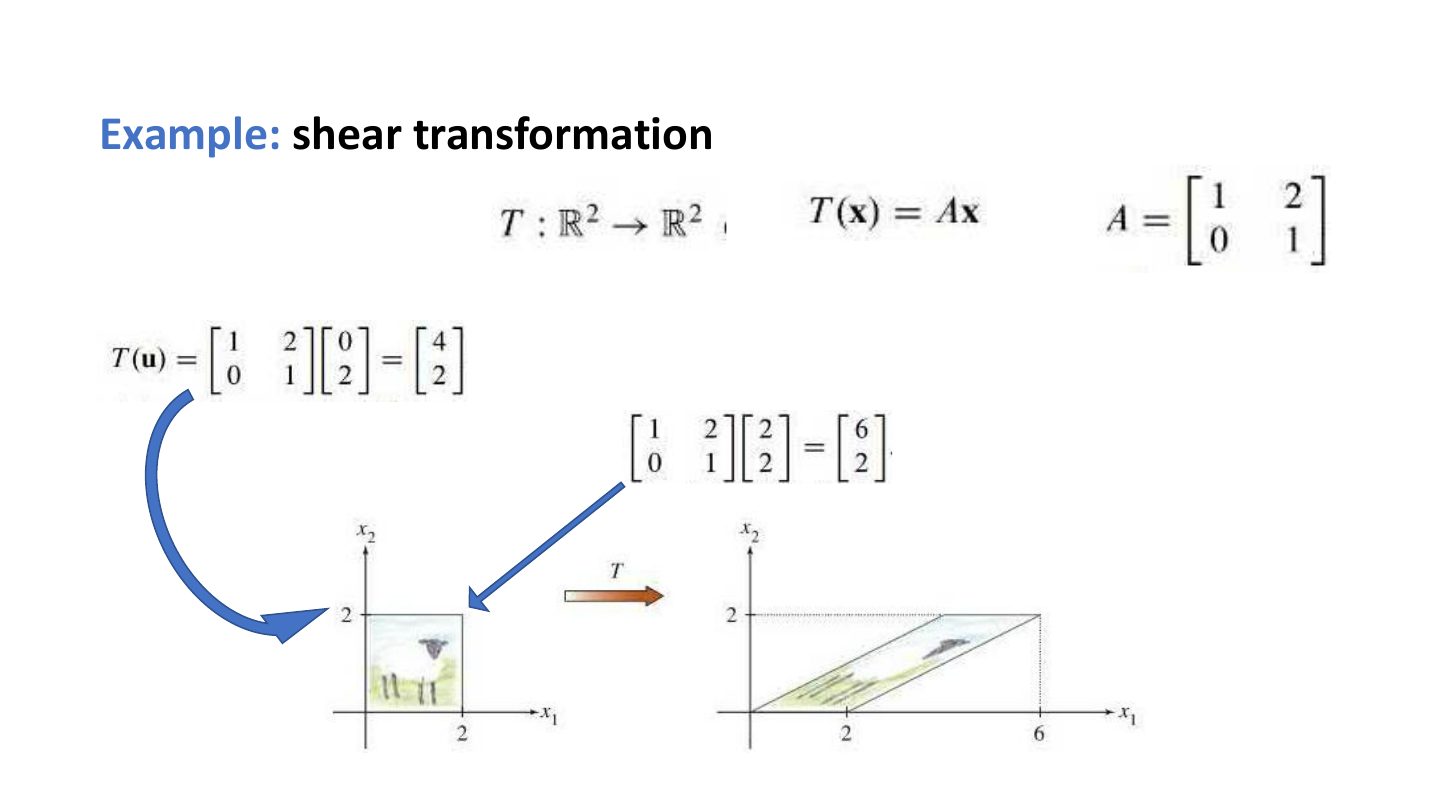
  11. 11 Example: shear transformation
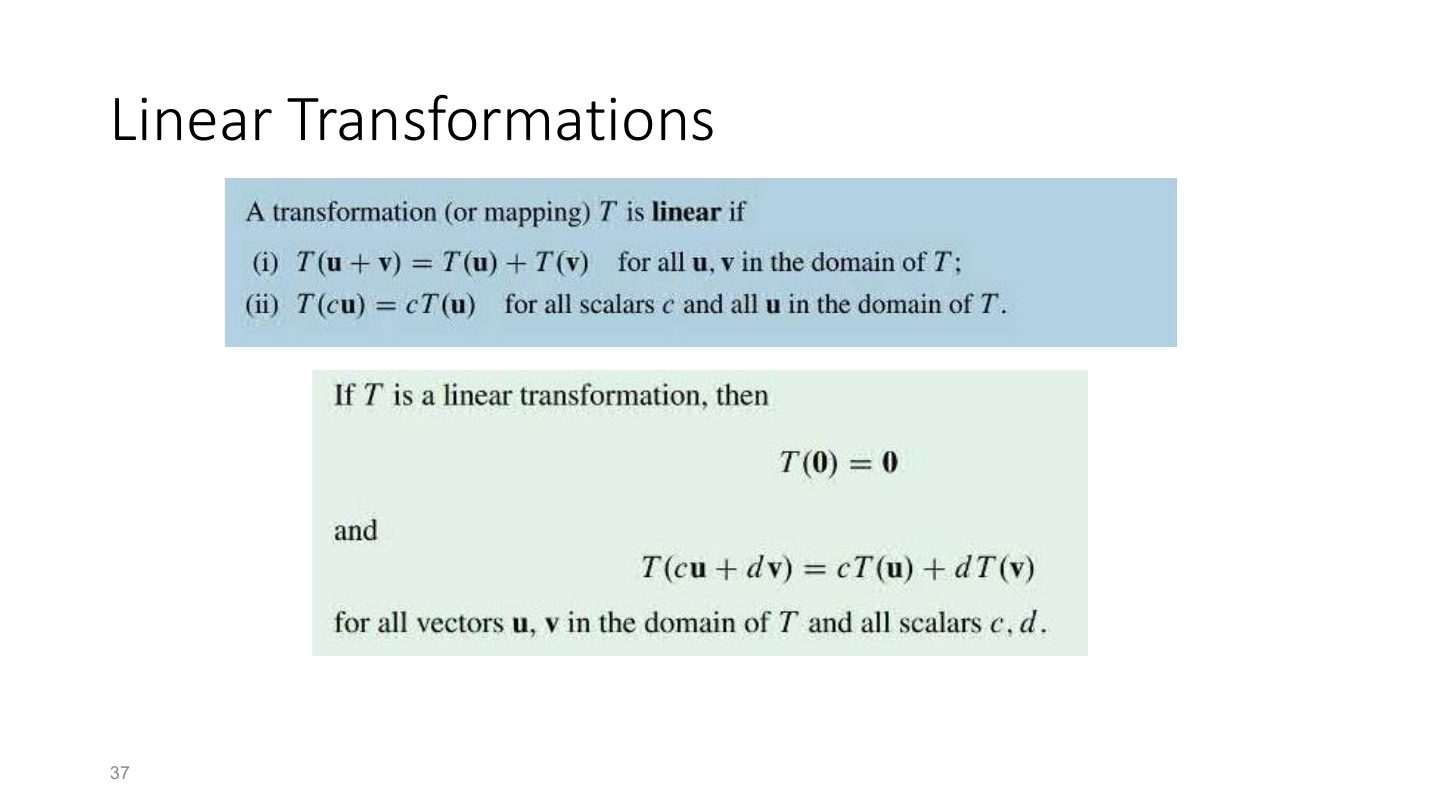
  12. 12 Linear Transformations
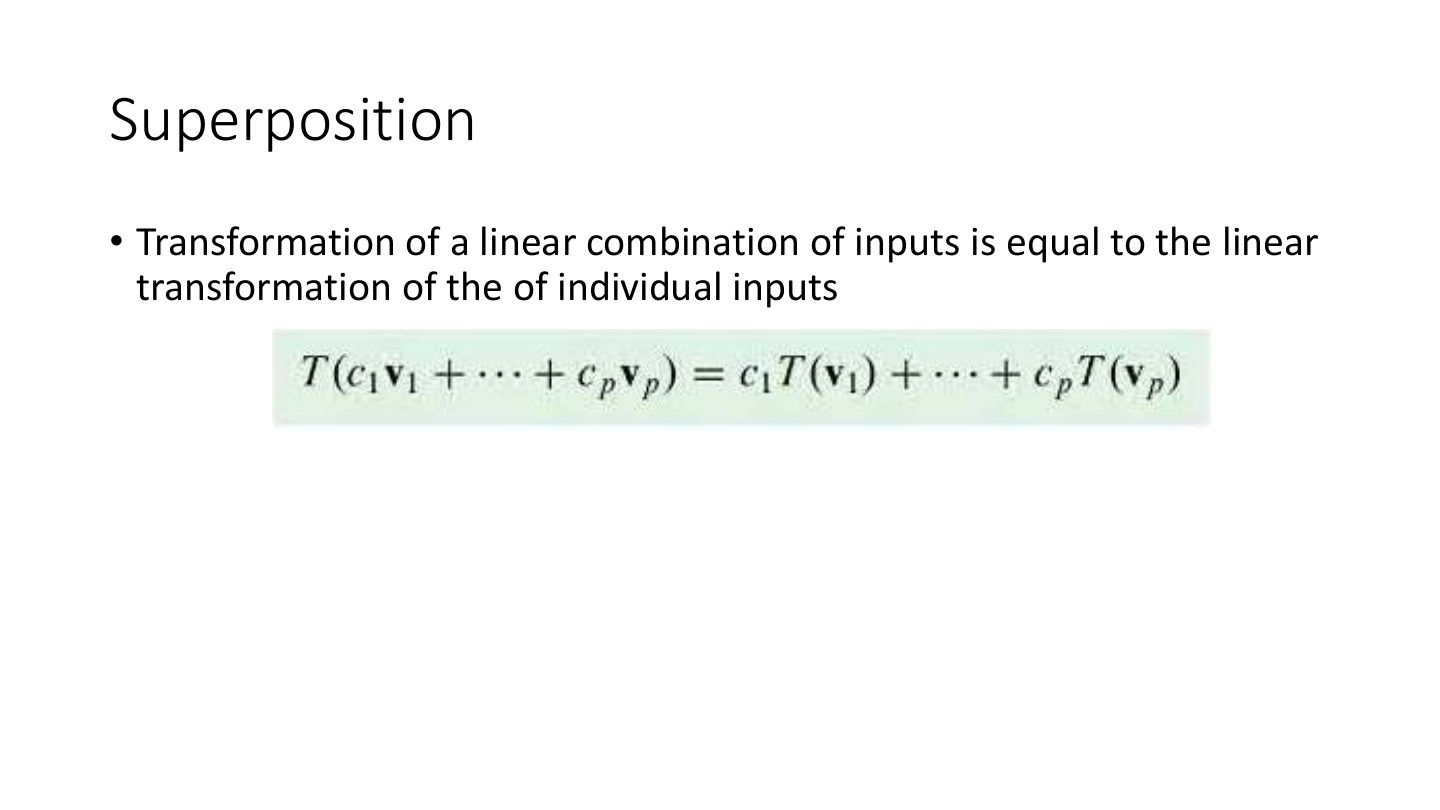
  13. 13 Superposition
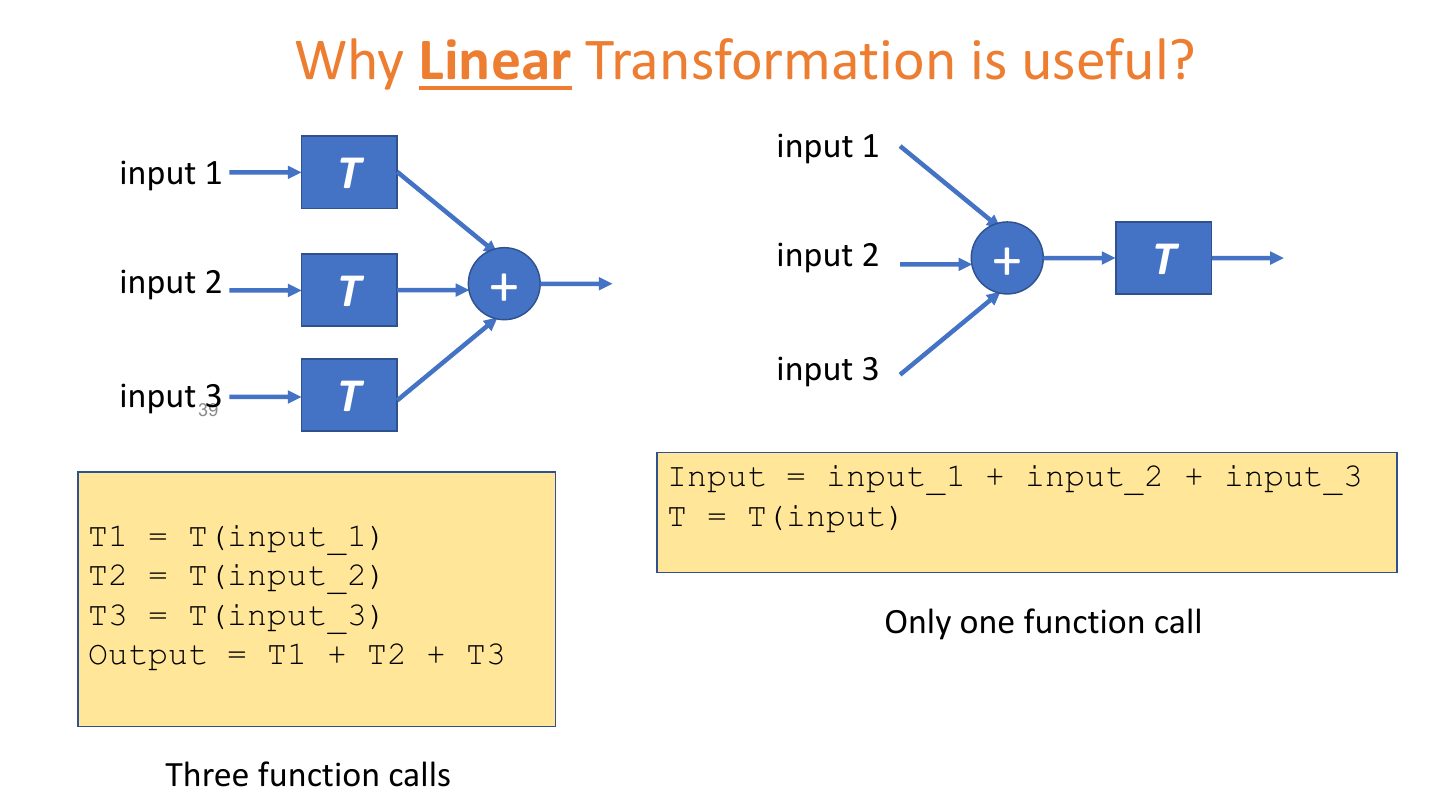
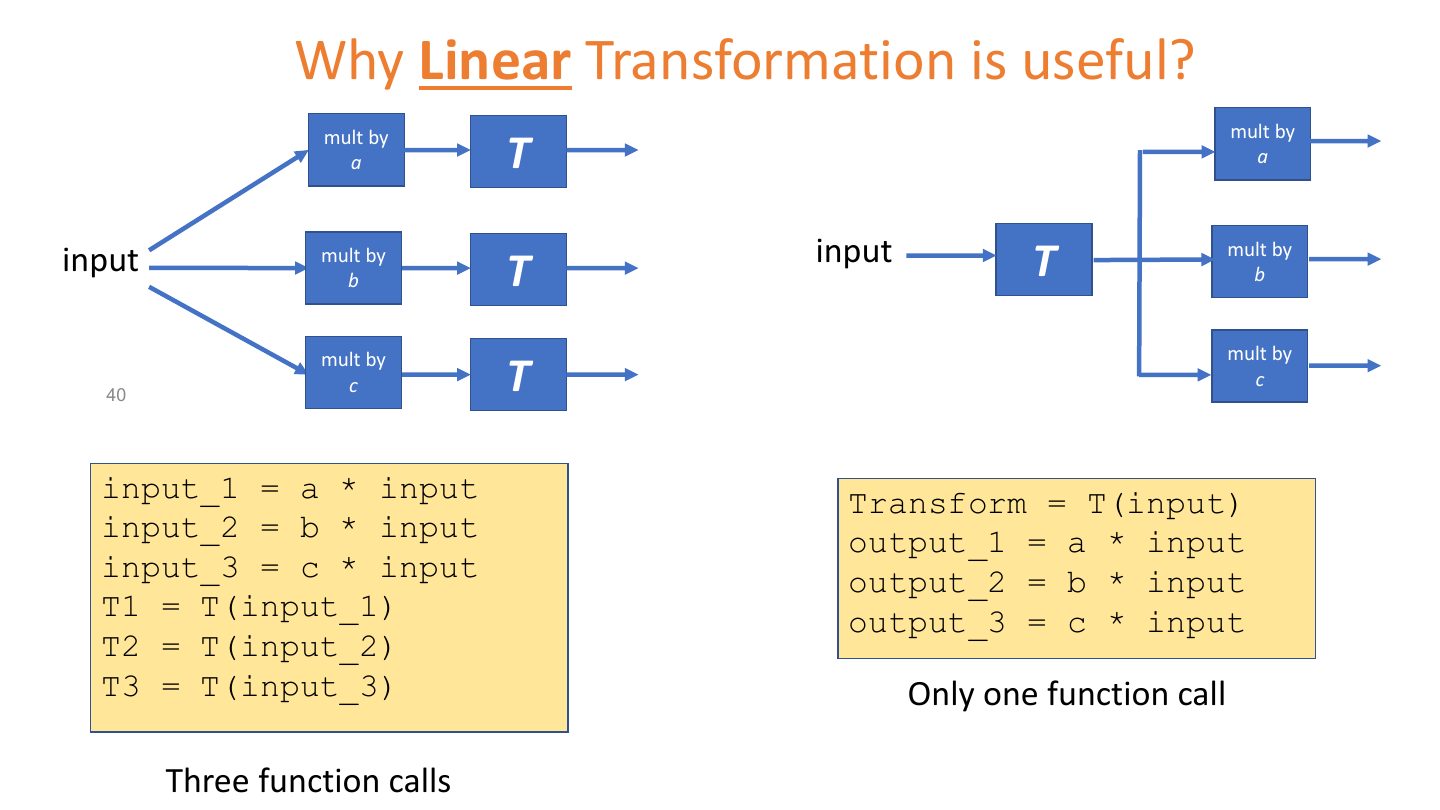
  14. 14 Why Linear Transformation is useful?
  15. 15 Why Linear Transformation is useful?
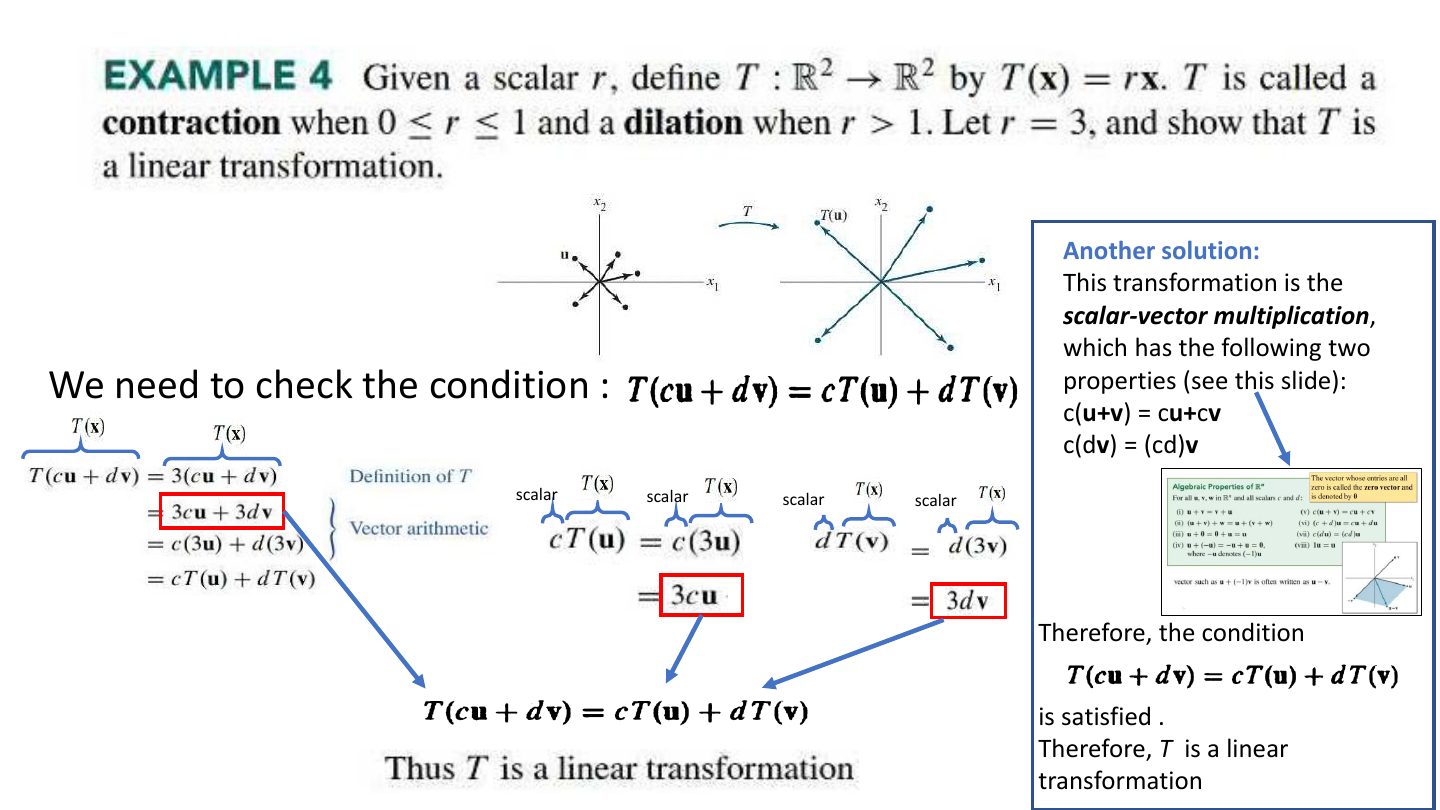
  16. 16 Another solution:
  17. 17 Slide 17
  18. 18 Slide 18
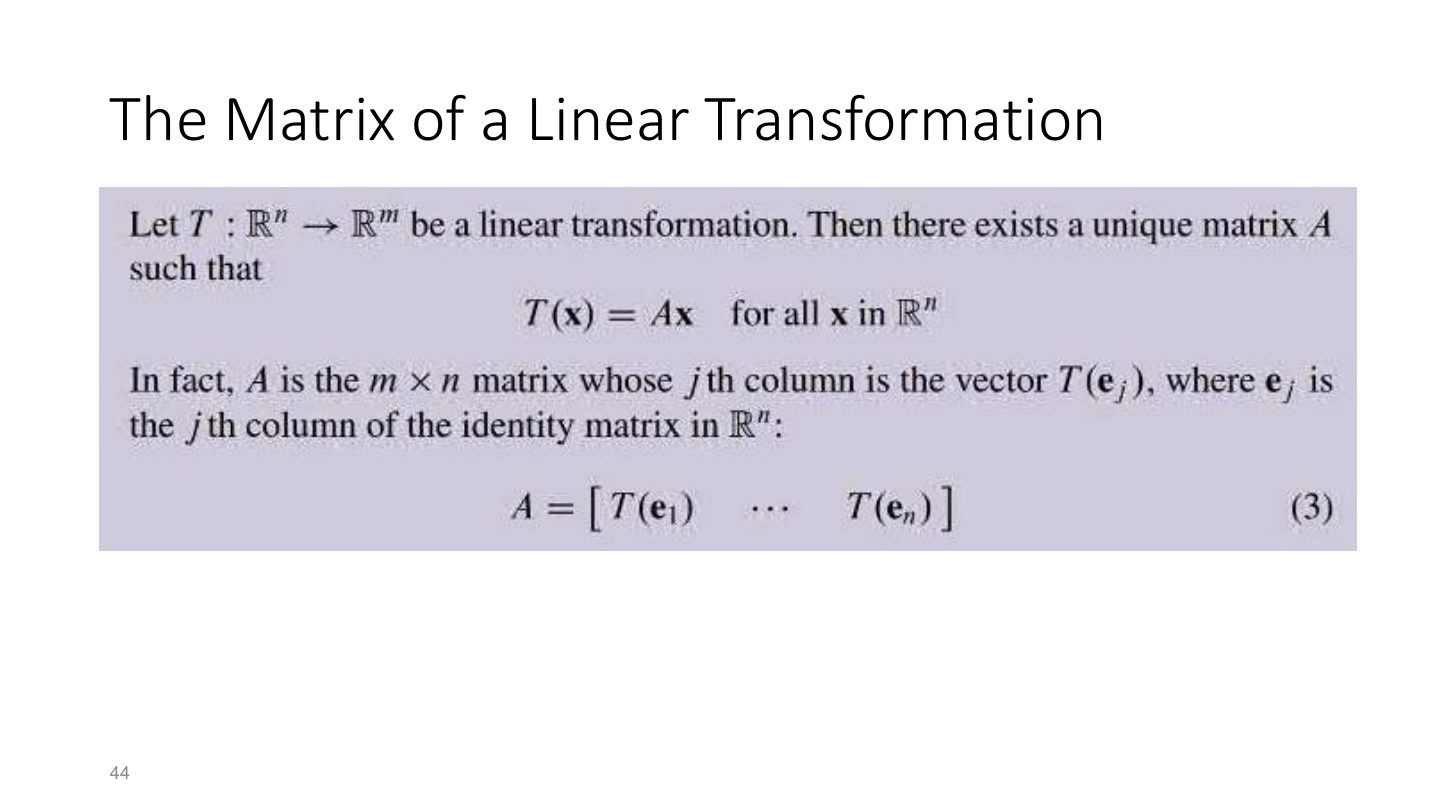
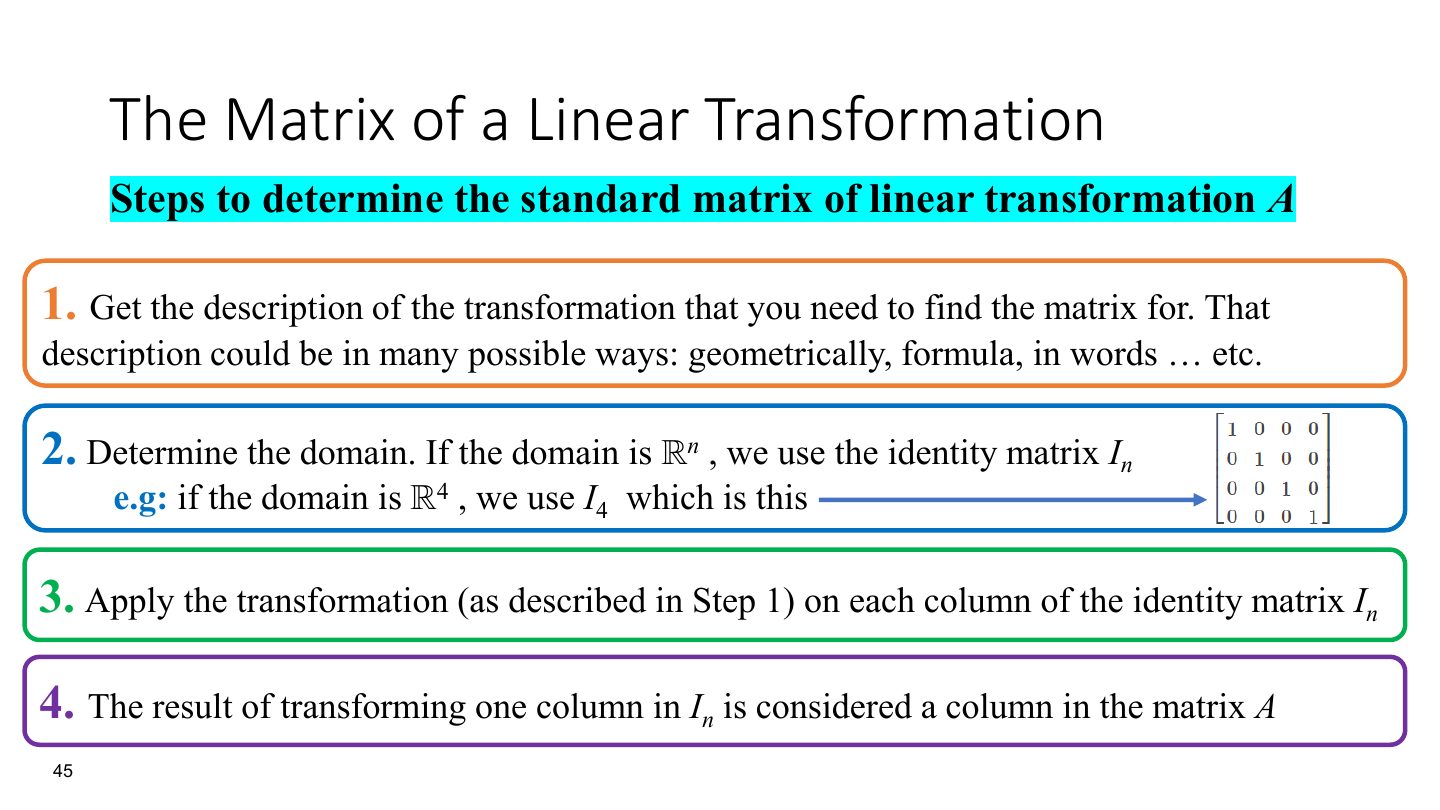
  19. 19 The Matrix of a Linear Transformation
  20. 20 The Matrix of a Linear Transformation
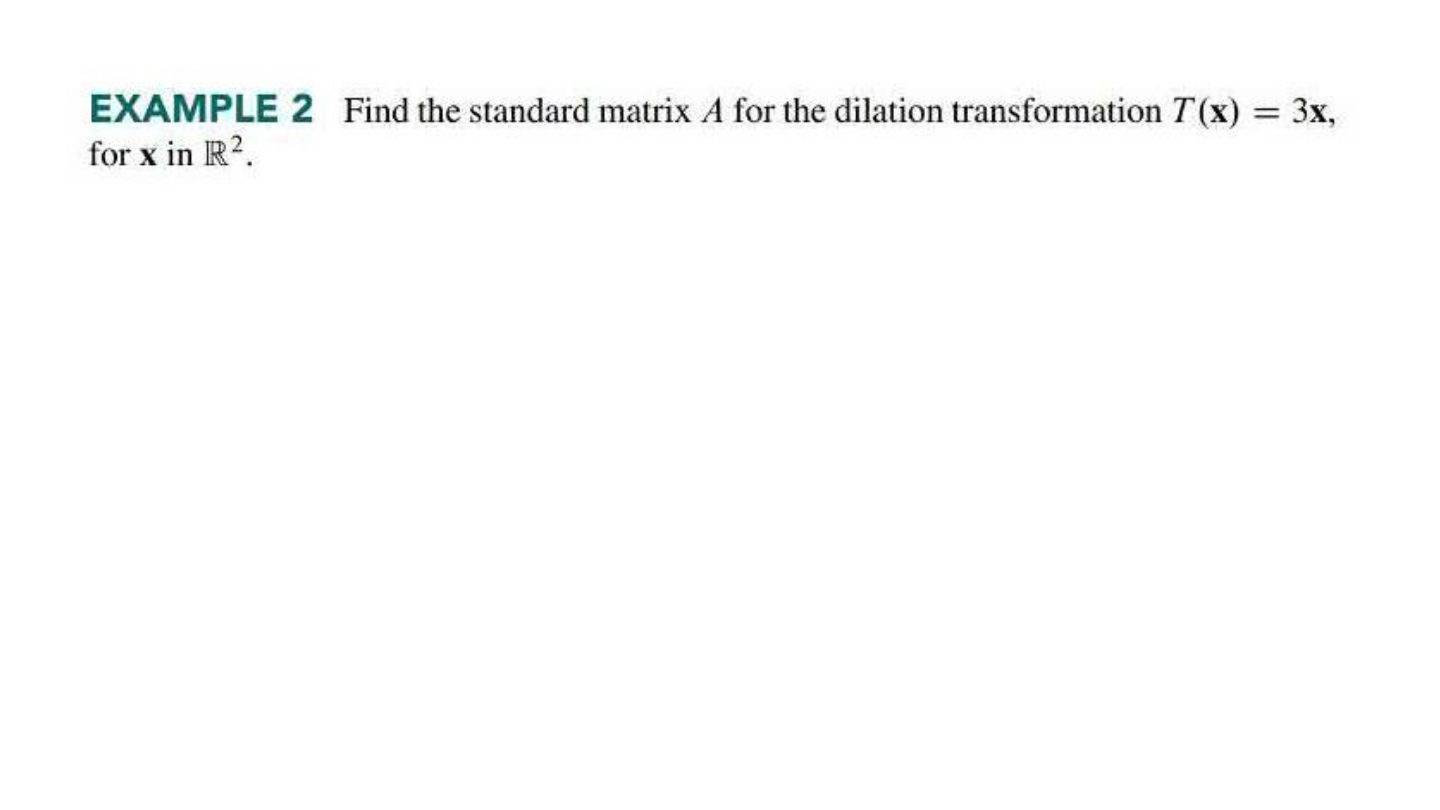
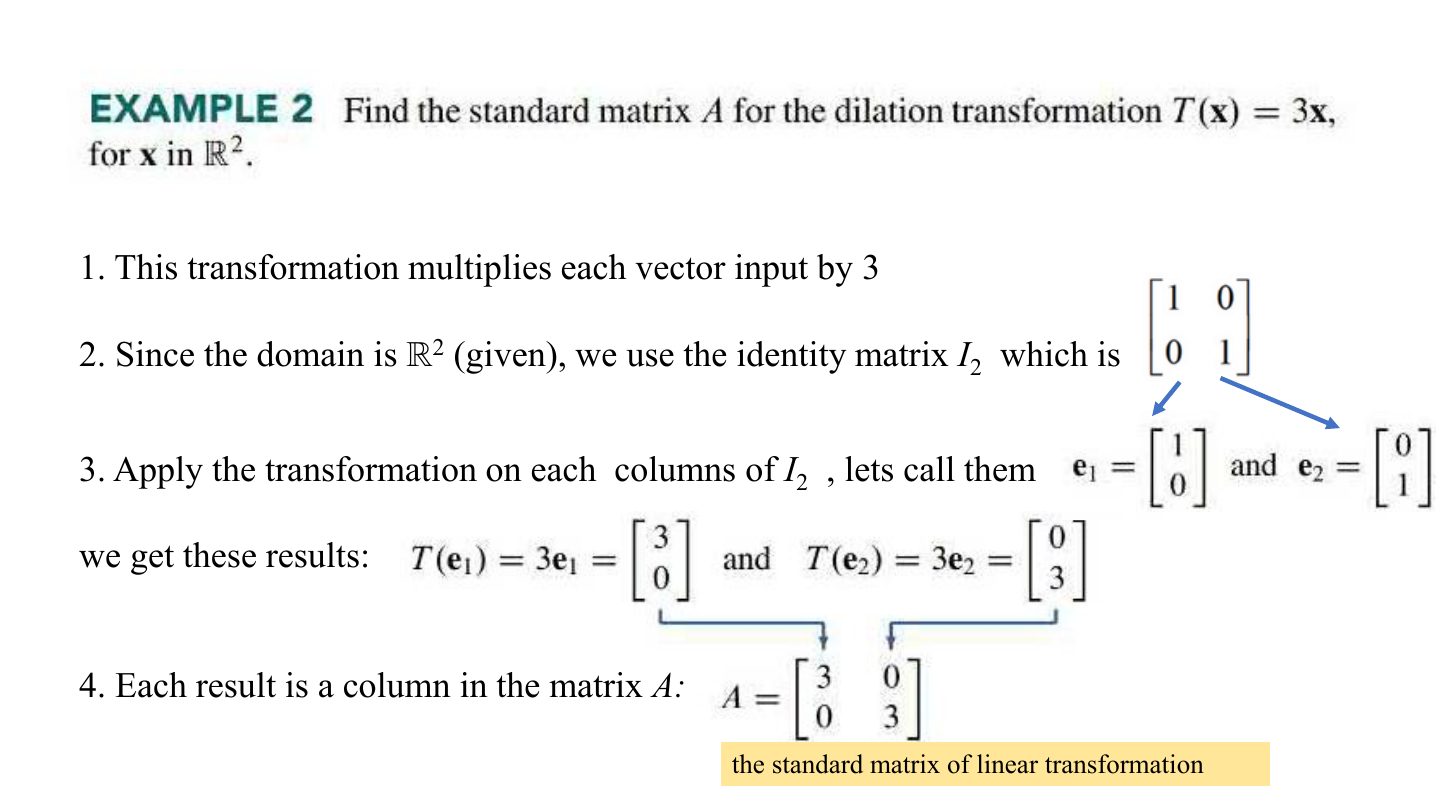
  21. 21 Slide 21
  22. 22 Slide 22
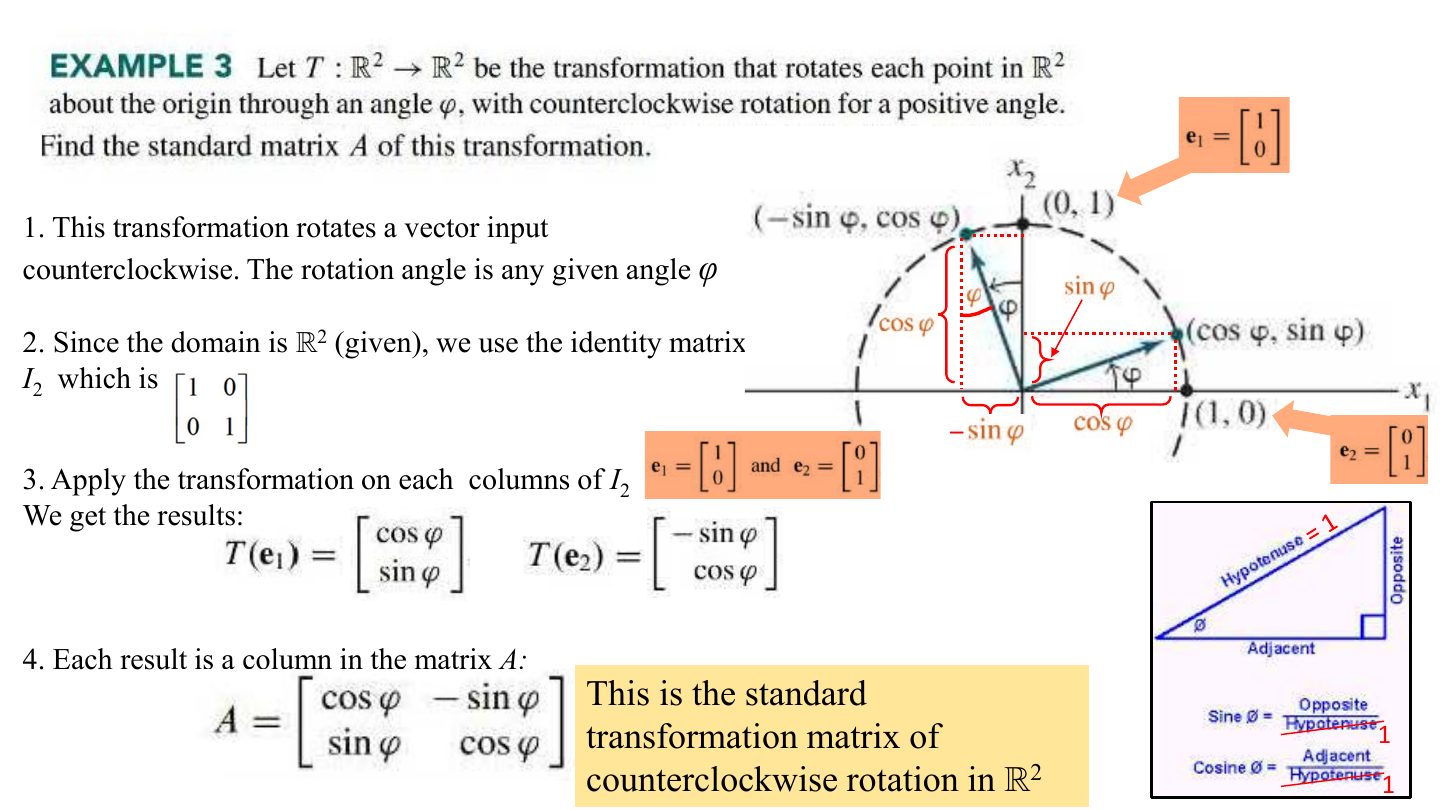
  23. 23 1. This transformation rotates a vector input
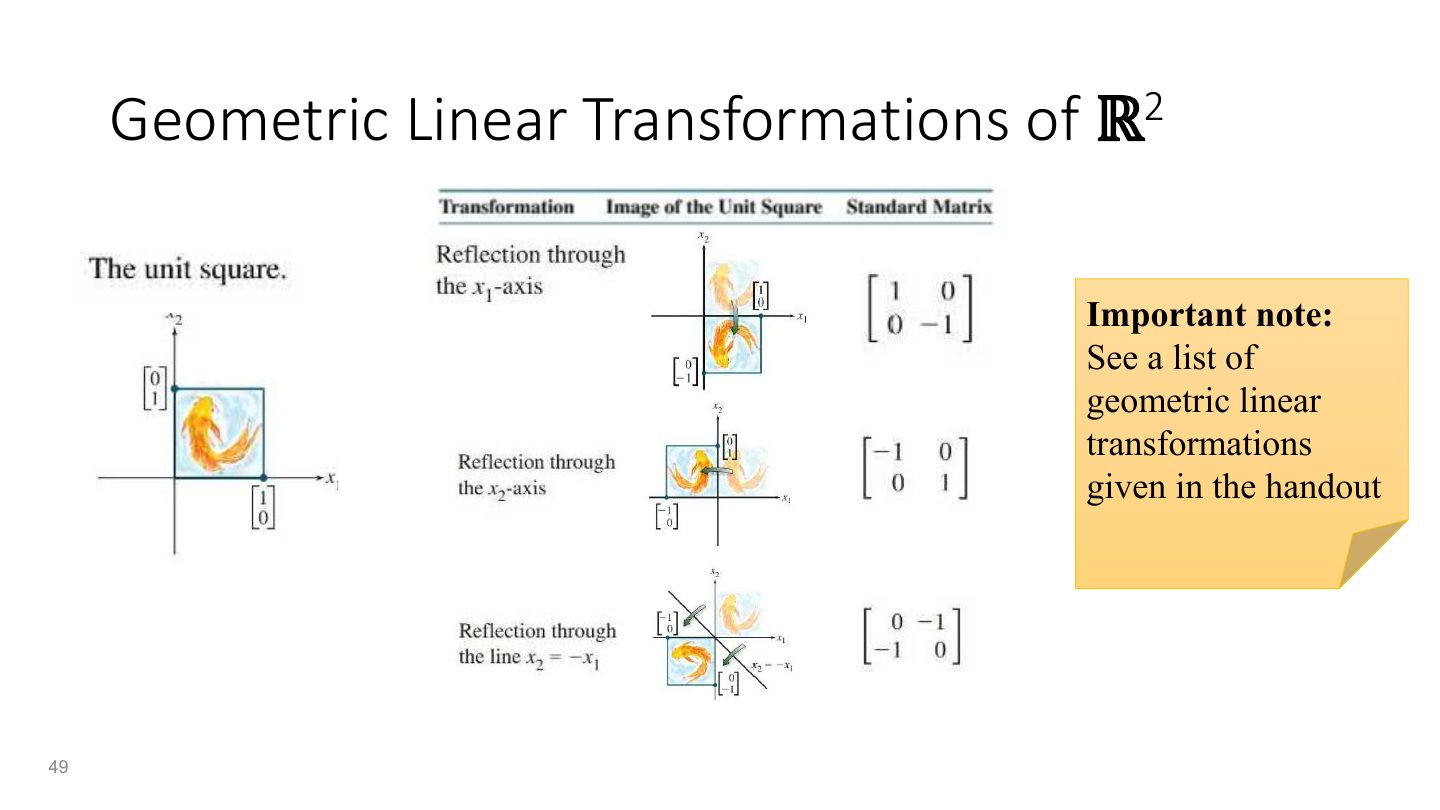
  24. 24 Geometric Linear Transformations of
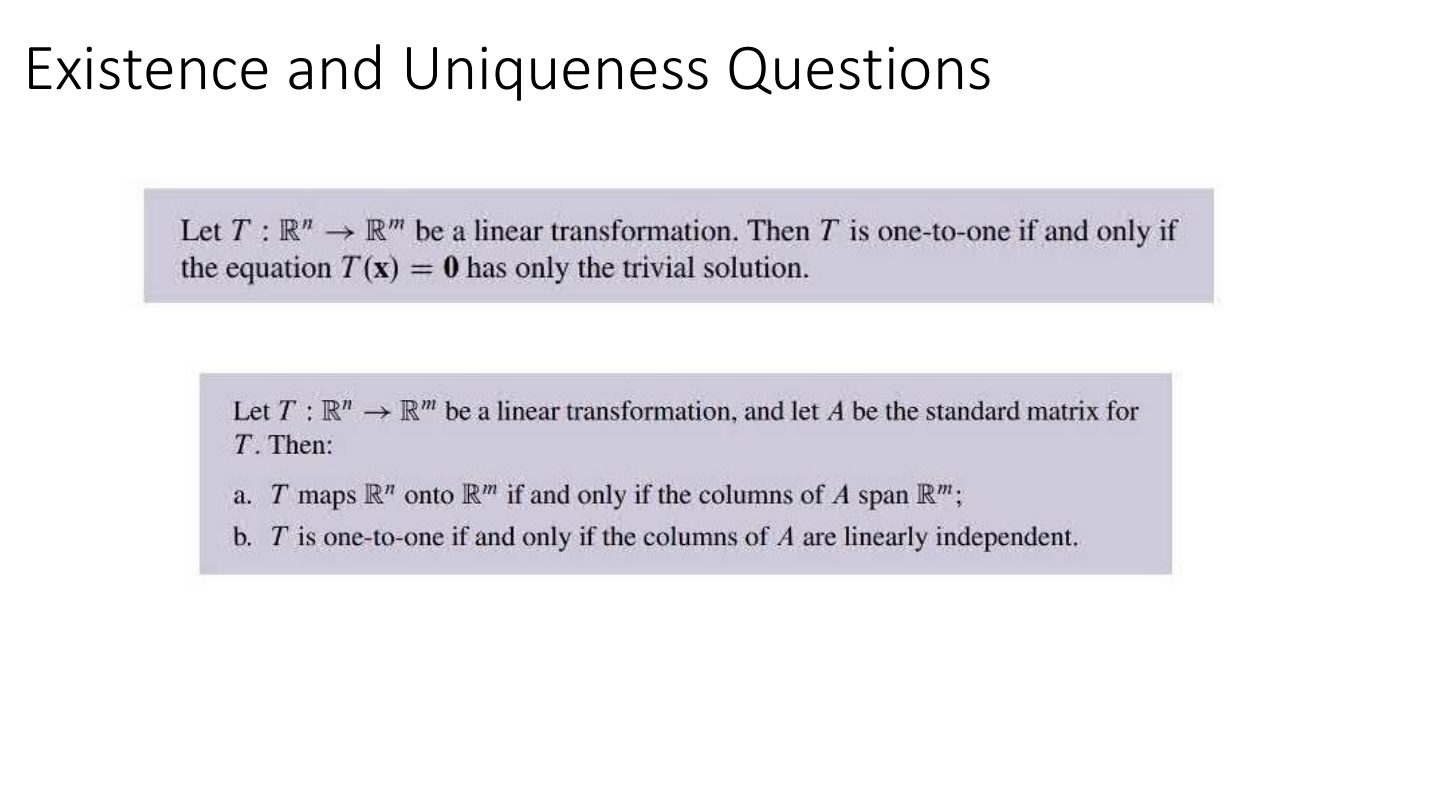
  25. 25 Existence and Uniqueness Questions
  26. 26 b
  27. 27 b
  28. 28 Existence and Uniqueness Questions
  29. 29 A yet. So, we find first A We don t have the standard matrix ’ Consult the following slides
  30. 30 A yet. So, we find first A We don t have the standard matrix ’ Consult the following slides 1. This transformation description:
  31. 31 Slide 31
  32. 32 Slide 32
  33. 33 Slide 33
Slide 1 / 33

Introduction to Linear Transformation

Slide 1: Introduction to Linear Transformation
Slide 2 / 33

Introduction to Linear Transformation

Slide 2: Introduction to Linear Transformation
Slide 3 / 33

Slide 3

Slide 3: Slide 3
Slide 4 / 33

Slide 4

Slide 4: Slide 4
Slide 5 / 33

Slide 5

Slide 5: Slide 5
Slide 6 / 33

Slide 6

Slide 6: Slide 6
Slide 7 / 33

Slide 7

Slide 7: Slide 7
Slide 8 / 33

We need to find whether has a unique solution

Slide 8: We need to find whether has a unique solution
Slide 9 / 33

Slide 9

Slide 9: Slide 9
Slide 10 / 33

Slide 10

Slide 10: Slide 10
Slide 11 / 33

Example: shear transformation

Slide 11: Example: shear transformation
Slide 12 / 33

Linear Transformations

Slide 12: Linear Transformations

Notes

  1. T is linear ⇔ T(u + v) = T(u) + T(v) and T(cu) = cT(u). Consequently T(0) = 0.

  2. Memory trick Quick test: if T(0) ≠ 0, T is NOT linear.

Exam angle

PredictionQ1

Which map is NOT linear?

Slide 13 / 33

Superposition

Slide 13: Superposition
Slide 14 / 33

Why Linear Transformation is useful?

Slide 14: Why Linear Transformation is useful?
Slide 15 / 33

Why Linear Transformation is useful?

Slide 15: Why Linear Transformation is useful?
Slide 16 / 33

Another solution:

Slide 16: Another solution:
Slide 17 / 33

Slide 17

Slide 17: Slide 17
Slide 18 / 33

Slide 18

Slide 18: Slide 18
Slide 19 / 33

The Matrix of a Linear Transformation

Slide 19: The Matrix of a Linear Transformation

Exam angle

PredictionQ1

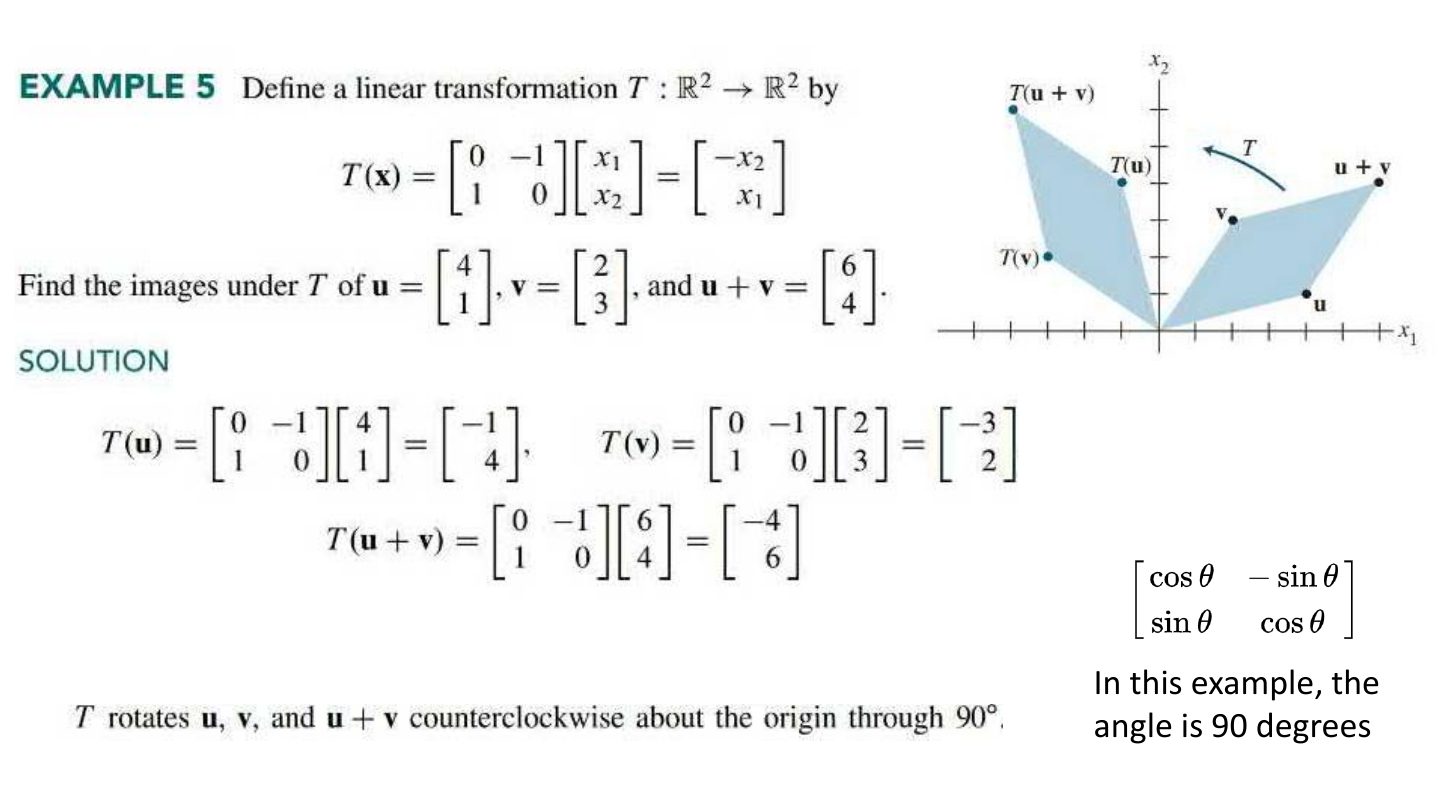
Find the standard matrix of the rotation of ℝ² by 90° counter-clockwise.

Compare with the model answer

T(e₁) = (0, 1), T(e₂) = (−1, 0), so A = [[0, −1], [1, 0]].
Slide 20 / 33

The Matrix of a Linear Transformation

Slide 20: The Matrix of a Linear Transformation
Slide 21 / 33

Slide 21

Slide 21: Slide 21
Slide 22 / 33

Slide 22

Slide 22: Slide 22
Slide 23 / 33

1. This transformation rotates a vector input

Slide 23: 1. This transformation rotates a vector input
Slide 24 / 33

Geometric Linear Transformations of

Slide 24: Geometric Linear Transformations of

Notes

  1. Geometric maps: reflections, contractions/expansions, shears, projections (see the tables).
Slide 25 / 33

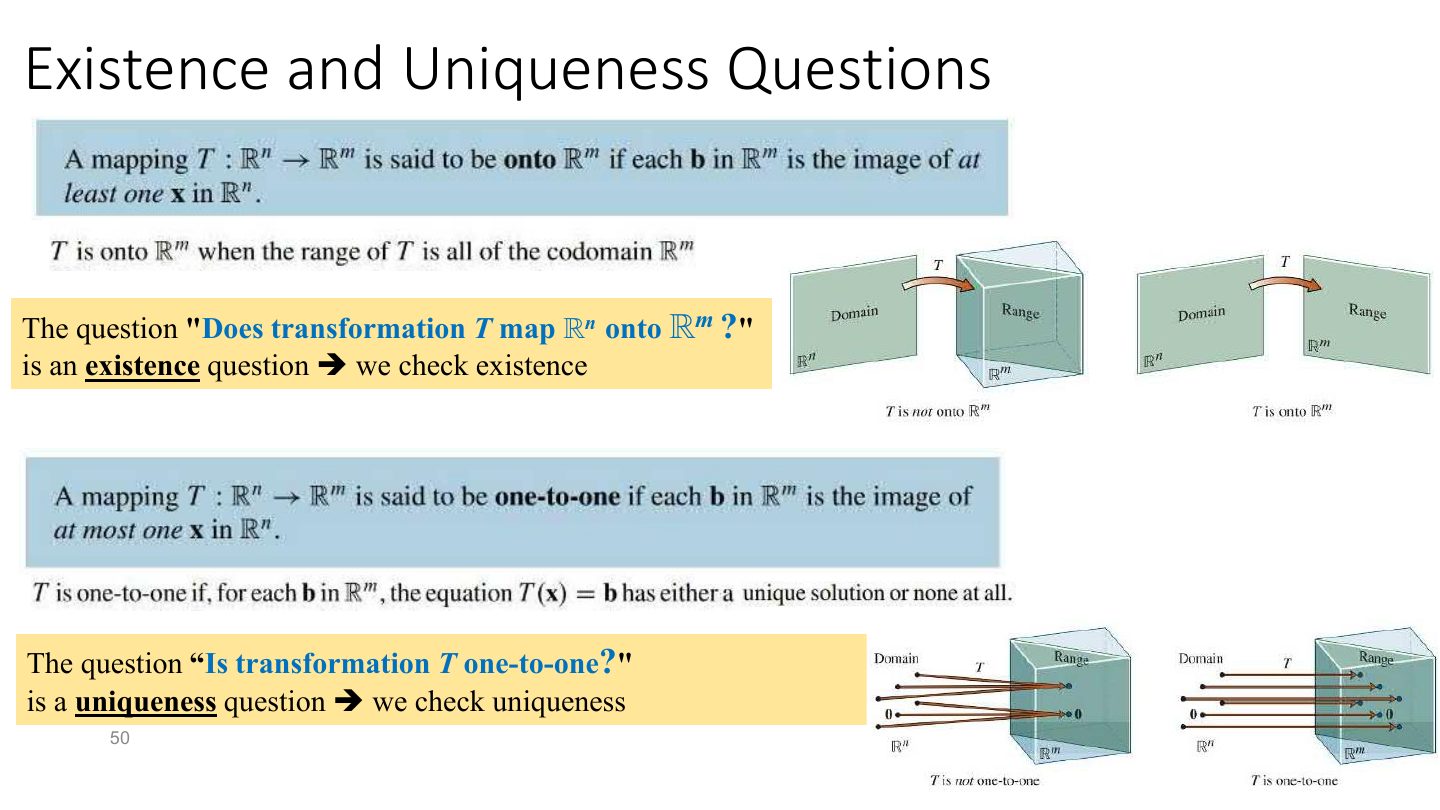
Existence and Uniqueness Questions

Slide 25: Existence and Uniqueness Questions

Notes

  1. Onto ℝᵐ ⇔ columns span ℝᵐ ⇔ pivot in every row. One-to-one ⇔ T(x) = 0 has only the trivial solution ⇔ columns independent ⇔ pivot in every column.

Exam angle

Past exam · Major 1 (251)

Related question: this topic is examined

PredictionQ1

T: ℝ³ → ℝ² can never be:

Slide 26 / 33

b

Slide 26: b
Slide 27 / 33

b

Slide 27: b
Slide 28 / 33

Existence and Uniqueness Questions

Slide 28: Existence and Uniqueness Questions
Slide 29 / 33

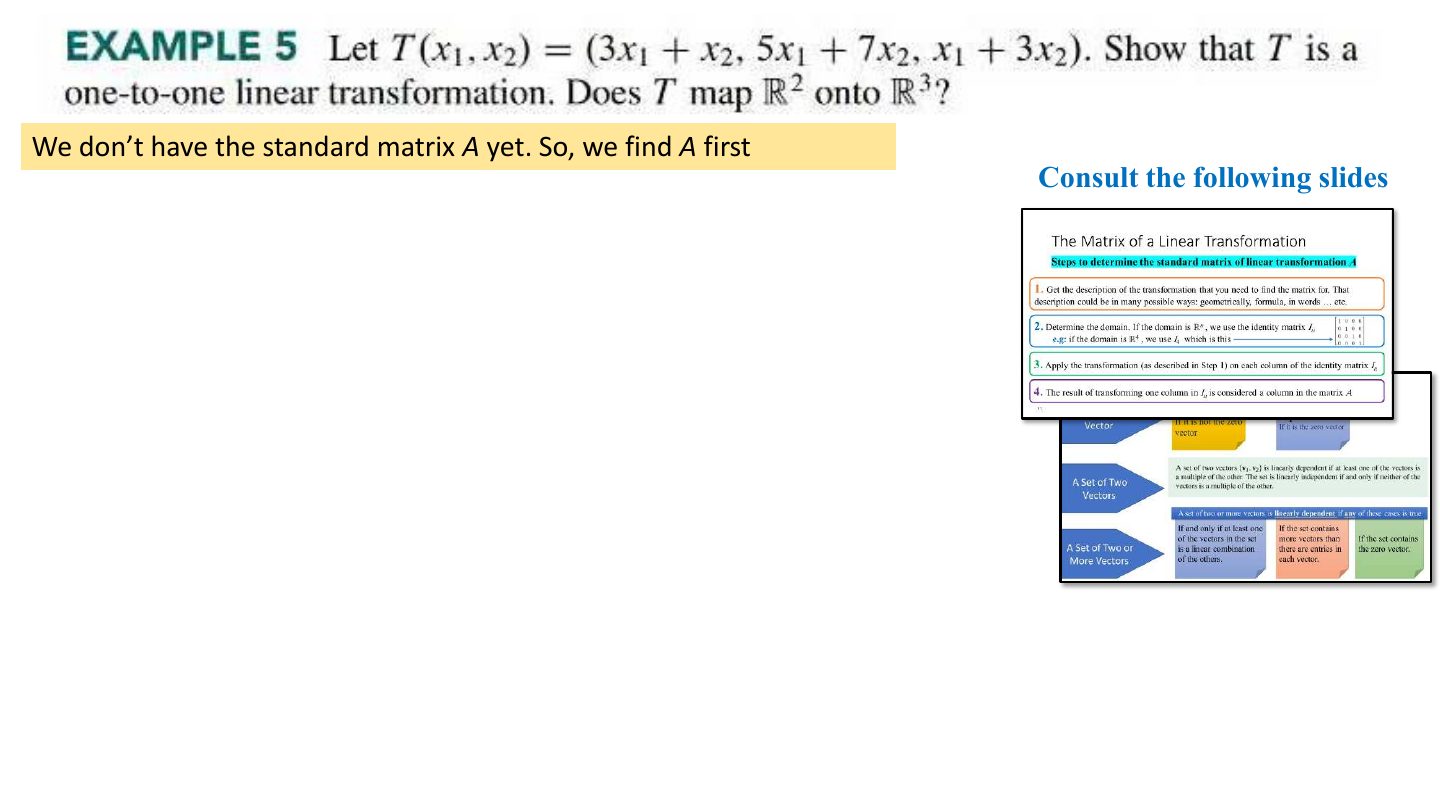
A yet. So, we find first A We don t have the standard matrix ’ Consult the following slides

Slide 29: A yet. So, we find first A We don t have the standard matrix ’ Consult the following slides
Slide 30 / 33

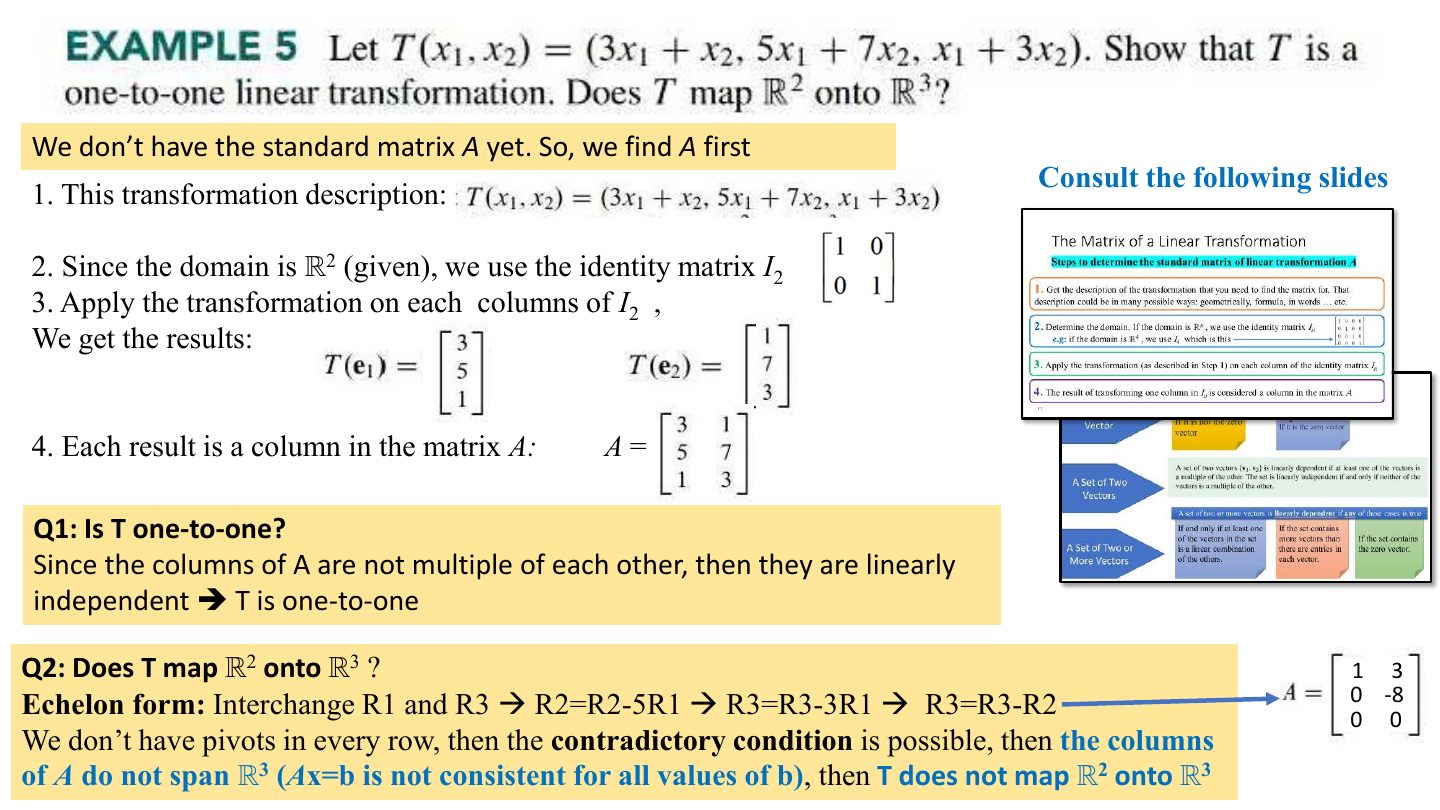
A yet. So, we find first A We don t have the standard matrix ’ Consult the following slides 1. This transformation description:

Slide 30: A yet. So, we find first A We don t have the standard matrix ’ Consult the following slides 1. This transformation description:
Slide 31 / 33

Slide 31

Slide 31: Slide 31
Slide 32 / 33

Slide 32

Slide 32: Slide 32
Slide 33 / 33

Slide 33

Slide 33: Slide 33